#include "math/quaternion.h"#include "math/transformops.h"#include "math/vector3.h"#include "os/prnstream.h"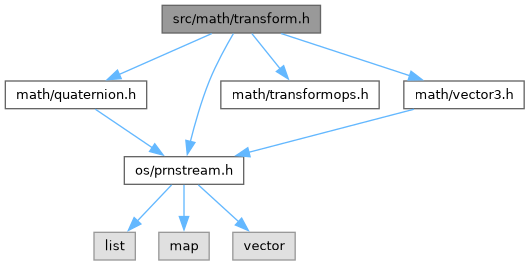

Go to the source code of this file.
Classes | |
| struct | Transform |
| Affine transform stored as three basis rows and a translation row. More... | |
Functions | |
| void | MultiplyPoint (const Transform &xfm, const Vector3 &v, Vector3 &out) |
| Transform a point by the basis rows and the translation of a transform. | |
| void | MultiplyVector (const Transform &xfm, const Vector3 &v, Vector3 &out) |
| Transform a direction by the basis rows of a transform, without the translation. | |
| void | Multiply (Transform &out, const Transform &first, const Transform &second) |
| Concatenate two transforms, applying the second and then the first, with sceVu0MulAffineMatrixXyz(). | |
| void | Invert (Transform &out, const Transform &xfm) |
| Invert a transform whose basis is orthonormal, with InversMatrix(). | |
| void | MakeScale (const Transform &xfm, Vector3 &scale) |
| Report the length of each basis row, negating the third when the basis is left handed, with Mat33ExtractScale(). | |
| PrnStream & | operator<< (PrnStream &stream, const Transform &transform) |
| Write the four rows of a transform. | |
Variables | |
| constexpr int | kTransformRowCount = 4 |
| Rows in a transform held as a bare array, three of the basis and the translation. | |
| constexpr int | kTransformRowFloatCount = 4 |
| Floats in a row of a transform held as a bare array, x, y, z, and padding. | |
Function Documentation
◆ MultiplyPoint()
Transform a point by the basis rows and the translation of a transform.
The binary expands the routine inline. The output may alias the point.
- Parameters
-
xfm The transform. v The point. out Receives the transformed point.
◆ MultiplyVector()
Transform a direction by the basis rows of a transform, without the translation.
The binary expands the routine inline. The output may alias the direction.
- Parameters
-
xfm The transform. v The direction. out Receives the transformed direction.
◆ Multiply()
Concatenate two transforms, applying the second and then the first, with sceVu0MulAffineMatrixXyz().
- Parameters
-
out Receives the concatenation. first The transform applied last, such as a parent's world transform. second The transform applied first, such as a child's local transform.
◆ Invert()
Invert a transform whose basis is orthonormal, with InversMatrix().
- Parameters
-
out Receives the inverse. It may not alias the source. xfm The transform.
◆ MakeScale()
Report the length of each basis row, negating the third when the basis is left handed, with Mat33ExtractScale().
- Parameters
-
xfm The transform. scale Receives the three lengths.
◆ operator<<()
Write the four rows of a transform.
- Parameters
-
stream The stream to write to. transform The transform.
- Returns
- The stream.
- Ghidra address:
- NTSC-U/C: 0x002930a0
- Ghidra address:
- PAL: 0x0029ca68
Variable Documentation
◆ kTransformRowCount
|
constexpr |
Rows in a transform held as a bare array, three of the basis and the translation.
◆ kTransformRowFloatCount
|
constexpr |
Floats in a row of a transform held as a bare array, x, y, z, and padding.