#include "common/vehicle.h"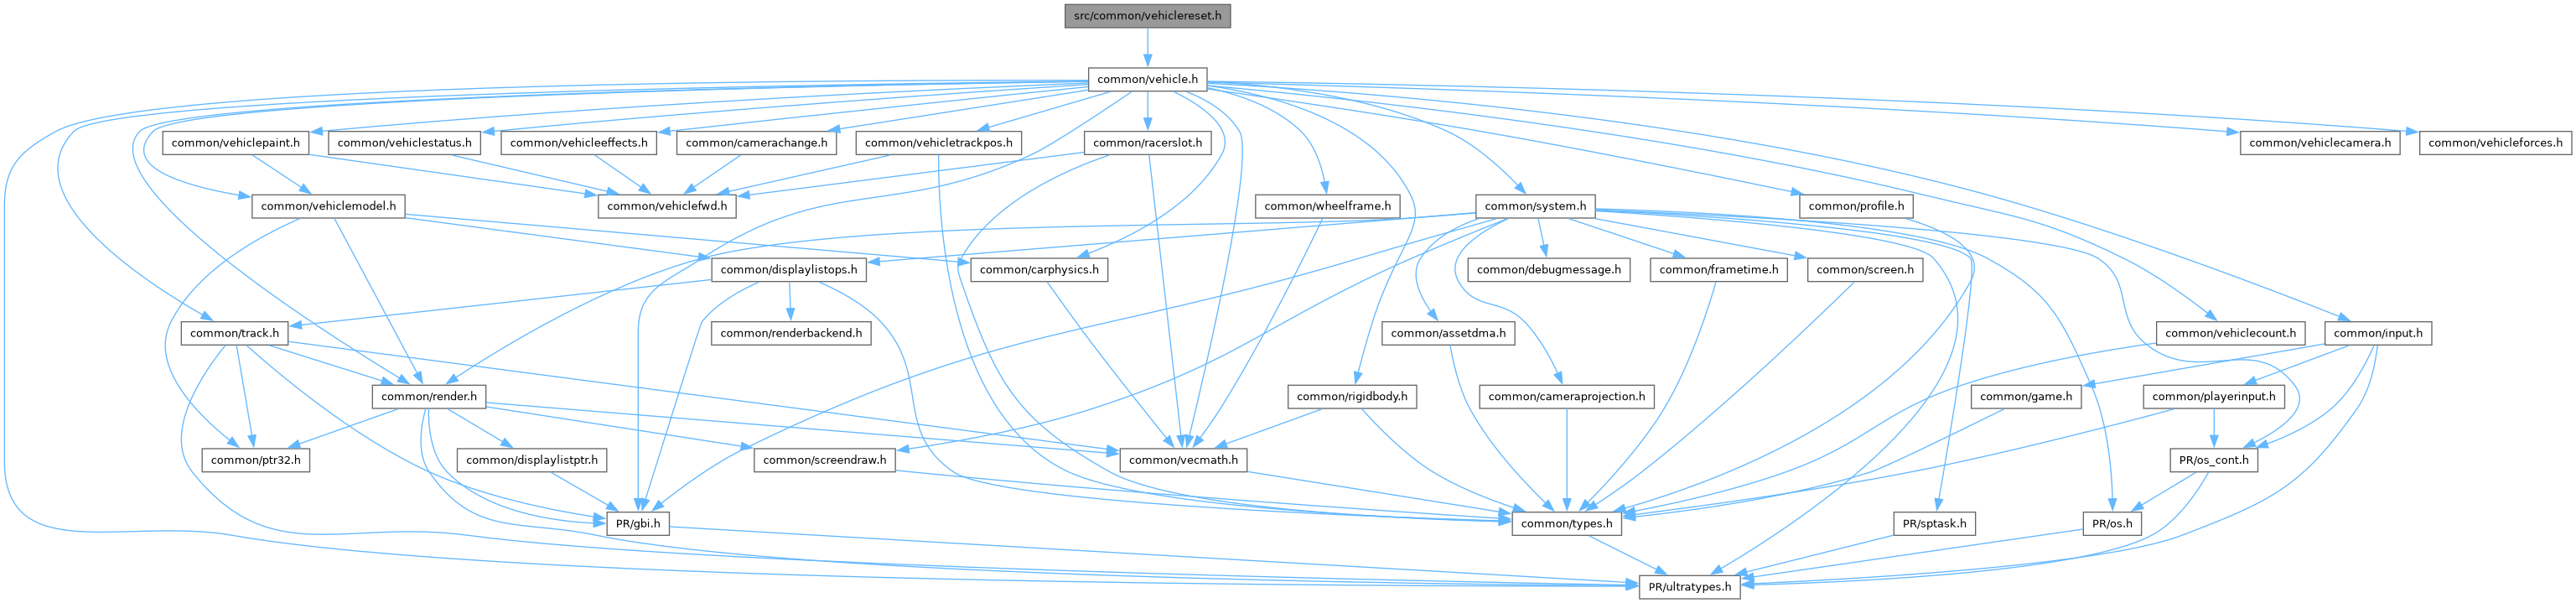
Go to the source code of this file.
Functions | |
| void | ResetVehicleState (Vehicle *vehicle) |
| Reset vehicle transforms and apply the selected car's physics. | |
| void | InitVehiclePhysics (Vehicle *vehicle) |
| Initialise the body, wheels, and force chains for the selected model. | |
| void | InitVehicleColorAndPhysics (Vehicle *vehicle) |
| Apply release-specific model paint and initialise physics. | |
| void | SetVehicleModelSlot (Vehicle *vehicle, s32 slot) |
| Bind a model slot and initialise its colour and physics. | |
| void | ClearVehicleDamageState (Vehicle *vehicle) |
| Clear dents and the dent variation. | |
| void | SetupVehicleForRaceStart (Vehicle *vehicle) |
| Place the vehicle on the starting grid and initialise race state. | |
| void | RespawnVehicle (Vehicle *vehicle) |
| Return an overturned or fallen vehicle to its current route point. | |
| void | SetVehicleVelocity (Vehicle *vehicle, f32 x, f32 y, f32 z) |
| Set velocity in the rigid-body integration states and the recorded placement. | |
| void | SetVehiclePosition (Vehicle *vehicle, f32 x, f32 y, f32 z) |
| Set the position in the frame, spray origin, and rigid-body integration states. | |
| void | InitVehicleOrientationFromAngle (Vehicle *vehicle, f32 angle) |
| Initialise the vehicle and integration orientations from a heading in radians. | |
| void | SetVehicleFrameMatrix (Vehicle *vehicle, f32(*m)[4]) |
| Set the frame matrix and copy its orientation to the integration states. | |
| void | RotateVehicleByEuler (Vehicle *vehicle, f32 yaw, f32 pitch, f32 roll) |
| Apply yaw, pitch, and roll rotations in radians to the integration orientations. | |
| void | SetVehicleTurnRate (Vehicle *vehicle, f32 x, f32 y, f32 z) |
| Set angular velocity in the rigid-body integration states. | |
Function Documentation
◆ ResetVehicleState()
| void ResetVehicleState | ( | Vehicle * | vehicle | ) |
Reset vehicle transforms and apply the selected car's physics.
- Parameters
-
vehicle The vehicle whose model and setup choices are already selected.
◆ InitVehiclePhysics()
| void InitVehiclePhysics | ( | Vehicle * | vehicle | ) |
Initialise the body, wheels, and force chains for the selected model.
- Parameters
-
vehicle The vehicle to initialise; a null model skips body and wheel initialisation.
◆ InitVehicleColorAndPhysics()
| void InitVehicleColorAndPhysics | ( | Vehicle * | vehicle | ) |
Apply release-specific model paint and initialise physics.
- Parameters
-
vehicle The vehicle whose model and colour selections have been populated.
◆ SetVehicleModelSlot()
Bind a model slot and initialise its colour and physics.
- Parameters
-
vehicle The vehicle receiving the selected model. slot A valid index in g_aVehicleModels.
◆ ClearVehicleDamageState()
| void ClearVehicleDamageState | ( | Vehicle * | vehicle | ) |
Clear dents and the dent variation.
- Parameters
-
vehicle The vehicle whose visual damage is reset.
◆ SetupVehicleForRaceStart()
| void SetupVehicleForRaceStart | ( | Vehicle * | vehicle | ) |
Place the vehicle on the starting grid and initialise race state.
- Parameters
-
vehicle The configured vehicle with a loaded model and assigned grid position.
◆ RespawnVehicle()
| void RespawnVehicle | ( | Vehicle * | vehicle | ) |
Return an overturned or fallen vehicle to its current route point.
- Parameters
-
vehicle The active vehicle with a valid track section and point index.
◆ SetVehicleVelocity()
Set velocity in the rigid-body integration states and the recorded placement.
- Parameters
-
vehicle The vehicle whose linear velocity changes. x The world x velocity, in world units per second. y The world y velocity, in world units per second. z The world z velocity, in world units per second.
◆ SetVehiclePosition()
Set the position in the frame, spray origin, and rigid-body integration states.
- Parameters
-
vehicle The vehicle to reposition. x The world x coordinate. y The world y coordinate. z The world z coordinate.
◆ InitVehicleOrientationFromAngle()
Initialise the vehicle and integration orientations from a heading in radians.
- Parameters
-
vehicle The vehicle whose orientation changes. angle The heading in the world XY plane, in radians about the z axis.
◆ SetVehicleFrameMatrix()
Set the frame matrix and copy its orientation to the integration states.
- Parameters
-
vehicle The vehicle whose frame and body orientation change. m The readable 4-by-4 frame matrix, copied during this call.
◆ RotateVehicleByEuler()
Apply yaw, pitch, and roll rotations in radians to the integration orientations.
- Parameters
-
vehicle The vehicle whose orientation changes. yaw The rotation about the local z axis, applied first, in radians. pitch The rotation about the local y axis, applied second, in radians. roll The rotation about the local x axis, applied last, in radians.
◆ SetVehicleTurnRate()
Set angular velocity in the rigid-body integration states.
- Parameters
-
vehicle The vehicle whose angular velocity changes. x The x component of angular velocity, in radians per second. y The y component of angular velocity, in radians per second. z The z component of angular velocity, in radians per second.
Generated by
 1.15.0