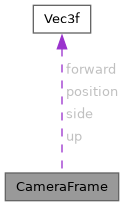
A frame of reference: three axes and a position, the rows of a 4 by 4 matrix whose last column FinishFrameMatrix() sets, and a field of view. More...
#include <render.h>
Public Attributes | |
| Vec3f | forward |
| f32 | forwardW |
| Vec3f | side |
| f32 | sideW |
| Vec3f | up |
| f32 | upW |
| Vec3f | position |
| f32 | positionW |
| f32 | fov |
Detailed Description
A frame of reference: three axes and a position, the rows of a 4 by 4 matrix whose last column FinishFrameMatrix() sets, and a field of view.
The world is z up. A vehicle and each of its cameras has one.
Member Data Documentation
◆ forward
| Vec3f CameraFrame::forward |
The axis pointing forward.
◆ forwardW
| f32 CameraFrame::forwardW |
The fourth column of the forward row, 0 after FinishFrameMatrix().
◆ side
| Vec3f CameraFrame::side |
The axis pointing to the side.
◆ sideW
| f32 CameraFrame::sideW |
The fourth column of the side row, 0 after FinishFrameMatrix().
◆ up
| Vec3f CameraFrame::up |
The axis pointing up.
◆ upW
| f32 CameraFrame::upW |
The fourth column of the up row, 0 after FinishFrameMatrix().
◆ position
| Vec3f CameraFrame::position |
The position in the world.
◆ positionW
| f32 CameraFrame::positionW |
The fourth column of the position row, 1 after FinishFrameMatrix().
◆ fov
| f32 CameraFrame::fov |
The field of view of a camera, in radians.
The documentation for this struct was generated from the following file:
- src/common/render.h
Generated by
 1.15.0