The rigid bodies of the physics: their state, forces and inertia, and the quaternion and 3 by 3 matrix arithmetic they use. More...
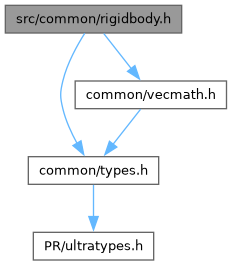
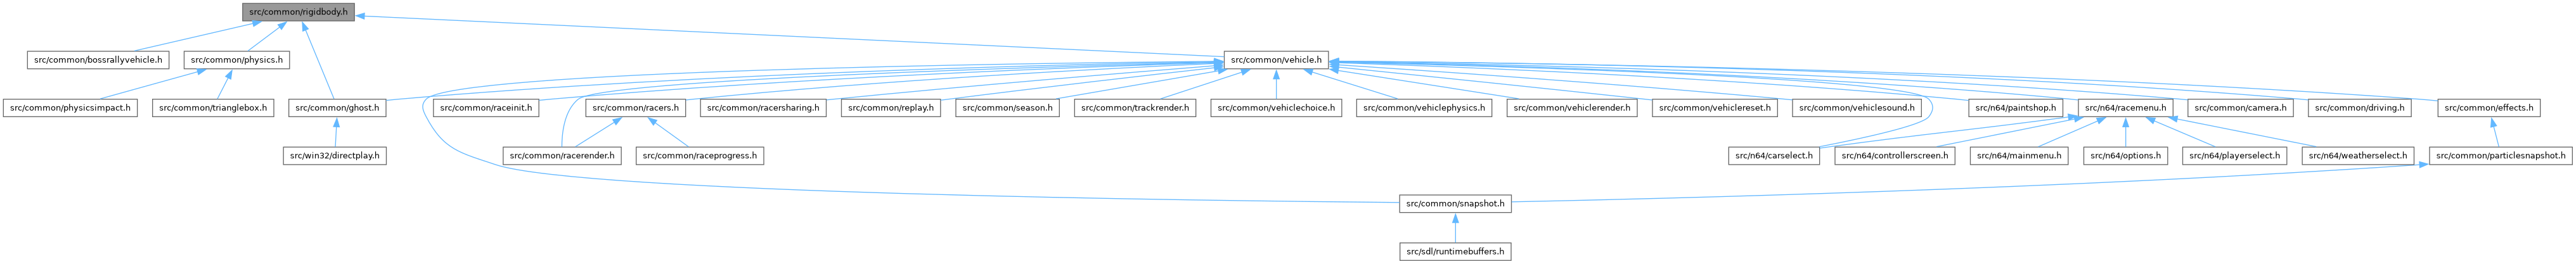
Go to the source code of this file.
Classes | |
| struct | Quaternion |
| A rotation as a unit quaternion. More... | |
| struct | RigidBodyState |
| The motion of a rigid body at an instant. More... | |
| struct | RigidBodyForce |
| A force on a rigid body, in a list. More... | |
| struct | RigidBody |
| A rigid body: the body of a vehicle or of one of its wheels. More... | |
Typedefs | |
| typedef struct RigidBodyForce | RigidBodyForce |
| A force on a rigid body, in a list. | |
| typedef struct RigidBody | RigidBody |
| A rigid body: the body of a vehicle or of one of its wheels. | |
Enumerations | |
| enum | { RIGID_BODY_FORCE_WORLD , RIGID_BODY_FORCE_BODY } |
| The frames a force can be given in. More... | |
| enum | { RIGID_BODY_BOX , RIGID_BODY_BOX_1 , RIGID_BODY_NO_ROTATION } |
| The kinds of rigid body. More... | |
Functions | |
| void | StubPhysics1 (void *data) |
| An empty hook the inertia setup calls. | |
| void | MatrixToQuaternion (f32 m[4][4], Quaternion *q) |
| The unit quaternion of the rotation of a matrix, from the largest of its diagonal terms. | |
| void | StubPhysics2 (void *data) |
| An empty hook QuaternionToMatrix() calls. | |
| void | QuaternionMultiply (Quaternion *out, Quaternion *a, Quaternion *b) |
| The product of two quaternions. | |
| void | QuaternionNormalize (Quaternion *q) |
| Make a quaternion a unit quaternion. | |
| void | Vec3fNormalizeFast (Vec3f *v) |
| Make a vector a unit vector. | |
| void | ComputeDeltaQuaternion (RigidBodyState *state) |
| The rate of change of the orientation from the angular velocity: half of the product of the angular velocity and the orientation. | |
| void | ApplyRigidBodyImpulse (RigidBodyState *state, RigidBody *body, f32 dt) |
| Add the force and torque of a body over a time to the velocity and angular velocity of a state. | |
| void | QuaternionToMatrix (f32 out[4][4], RigidBodyState *state) |
| The 4 by 4 matrix of the orientation and position of a state. | |
| void | IntegrateRigidBodyState (RigidBodyState *out, RigidBodyState *in, f32 dt) |
| Advance a state by a time, keeping its velocities. | |
| void | SetRigidBodyForce (RigidBodyForce *force, f32 x, f32 y, f32 z, f32 pointX, f32 pointY, f32 pointZ, s32 frame) |
| Set the vector, the point, and the frame of a force. | |
| void | Mtx4fInverseRotate (Vec3f *out, f32 m[4][4], Vec3f *v) |
| The dot products of the rotation rows of a matrix with a vector, which turns a vector of the world into the frame of the matrix. | |
| void | Mtx3x3MulVec3f (Vec3f *out, f32 m[4][4], Vec3f *v) |
| A vector times the rotation of a matrix, which turns a vector of the frame into the world. | |
| void | Mtx4x4TransformPoint (Vec3f *out, f32 m[4][4], Vec3f *v) |
| A point times a matrix, with its translation. | |
| void | Mtx3fMulVec3f (Vec3f *out, f32 m[3][3], Vec3f *v) |
| A 3 by 3 matrix times a column vector. | |
| void | ComputeRigidBodyAcceleration (RigidBody *body) |
| Turn the summed force and torque of a body into its accelerations. | |
| void | ApplySingleForceWithDebug (RigidBody *body, RigidBodyForce *force) |
| Add a force and its torque to the sums of a body, and print both on the debug output. | |
| void | ApplyAllForcesToBody (RigidBody *body) |
| Add each force of the list of a body to its sums of force and torque, printing each on the debug output. | |
| void | InitRigidBody (RigidBody *body) |
| Reset a body, and set the inertia of a box from its size and mass. | |
| void | BuildSkewSymmetricMatrix (f32 out[3][3], Vec3f *v) |
| The matrix of the cross product with a vector. | |
| void | TransposeCopyMatrix3x3 (f32 transpose[3][3], f32 copy[3][3], f32 m[4][4]) |
| Copy the rotation of a matrix, and its transpose. | |
| void | Transpose4x4Into3x3 (f32 out[3][3], f32 m[4][4]) |
| The transpose of the rotation of a matrix. | |
| void | CopyMatrix4x4To3x3 (f32 out[3][3], f32 m[4][4]) |
| Copy the rotation of a matrix. | |
| void | Mtx3fMultiply (f32 out[3][3], f32 a[3][3], f32 b[3][3]) |
| The product of two 3 by 3 matrices. | |
| void | SubtractMatrix3x3 (f32 out[3][3], f32 a[3][3], f32 b[3][3]) |
| The difference of two 3 by 3 matrices. | |
| void | MtxBuildScaledInverse (f32 m[4][4], f32 out[4][4], Vec3f *scale) |
| The inverse of a rigid transform whose axes are scaled. | |
| void | SolveLinearSystem3x3 (Vec3f *out, f32 a[3][3], Vec3f *b) |
| Solve a system of three linear equations by Cramer's rule. | |
Detailed Description
The rigid bodies of the physics: their state, forces and inertia, and the quaternion and 3 by 3 matrix arithmetic they use.
A 3 by 3 matrix is packed in nine words; the rotation part of a 4 by 4 matrix is its first three rows.
Typedef Documentation
◆ RigidBodyForce
| typedef struct RigidBodyForce RigidBodyForce |
A force on a rigid body, in a list.
◆ RigidBody
| typedef struct RigidBody RigidBody |
A rigid body: the body of a vehicle or of one of its wheels.
A wheel uses the ground, steering, spin and suspension fields, the body of a vehicle the springs, box and collision fields.
Enumeration Type Documentation
◆ anonymous enum
| anonymous enum |
◆ anonymous enum
| anonymous enum |
Function Documentation
◆ StubPhysics1()
| void StubPhysics1 | ( | void * | data | ) |
An empty hook the inertia setup calls.
- Parameters
-
data The inertia of the body, ignored.
- Ghidra address:
- USA: 0x80258070
- Ghidra address:
- Asia: 0x80257BC0
- Ghidra address:
- EUR: 0x80259640
- Ghidra address:
- JPN: 0x80258fd0
◆ MatrixToQuaternion()
| void MatrixToQuaternion | ( | f32 | m[4][4], |
| Quaternion * | q ) |
The unit quaternion of the rotation of a matrix, from the largest of its diagonal terms.
- Parameters
-
m The matrix. q Receives the quaternion.
- Ghidra address:
- USA: 0x8021ff90
- Ghidra address:
- Asia: 0x8021FAE0
- Ghidra address:
- EUR: 0x80221290
- Ghidra address:
- JPN: 0x80220a80
- Ghidra address:
- BRD3D: 0x100765e0
- Ghidra address:
- BRGlide: 0x1006f840
◆ StubPhysics2()
| void StubPhysics2 | ( | void * | data | ) |
An empty hook QuaternionToMatrix() calls.
- Parameters
-
data The matrix just built, ignored.
- Ghidra address:
- USA: 0x80258078
- Ghidra address:
- Asia: 0x80257BC8
- Ghidra address:
- EUR: 0x80259648
- Ghidra address:
- JPN: 0x80258fd8
- Ghidra address:
- BRD3D: 0x10008b80
- Ghidra address:
- BRGlide: 0x10008d60
◆ QuaternionMultiply()
| void QuaternionMultiply | ( | Quaternion * | out, |
| Quaternion * | a, | ||
| Quaternion * | b ) |
The product of two quaternions.
- Parameters
-
out Receives a times b, and may be either factor. a The left factor. b The right factor.
- Ghidra address:
- USA: 0x80258080
- Ghidra address:
- Asia: 0x80257BD0
- Ghidra address:
- EUR: 0x80259650
- Ghidra address:
- JPN: 0x80258fe0
- Ghidra address:
- BRD3D: 0x10074090
- Ghidra address:
- BRGlide: 0x1006d2e0
◆ QuaternionNormalize()
| void QuaternionNormalize | ( | Quaternion * | q | ) |
Make a quaternion a unit quaternion.
- Parameters
-
q The quaternion, normalised in place.
- Ghidra address:
- USA: 0x8025813c
- Ghidra address:
- Asia: 0x80257C8C
- Ghidra address:
- EUR: 0x8025970c
- Ghidra address:
- JPN: 0x8025909c
- Ghidra address:
- BRD3D: 0x100741b0
- Ghidra address:
- BRGlide: 0x1006d410
◆ Vec3fNormalizeFast()
| void Vec3fNormalizeFast | ( | Vec3f * | v | ) |
Make a vector a unit vector.
- Parameters
-
v The non-zero vector, normalised in place.
- Ghidra address:
- USA: 0x802581cc
- Ghidra address:
- Asia: 0x80257D1C
- Ghidra address:
- EUR: 0x8025979c
- Ghidra address:
- JPN: 0x8025912c
- Ghidra address:
- BRD3D: 0x10074250
- Ghidra address:
- BRGlide: 0x1006d4b0
◆ ComputeDeltaQuaternion()
| void ComputeDeltaQuaternion | ( | RigidBodyState * | state | ) |
The rate of change of the orientation from the angular velocity: half of the product of the angular velocity and the orientation.
- Parameters
-
state The state whose spin is set.
- Ghidra address:
- USA: 0x80258248
- Ghidra address:
- Asia: 0x80257D98
- Ghidra address:
- EUR: 0x80259818
- Ghidra address:
- JPN: 0x802591a8
- Ghidra address:
- BRD3D: 0x100742d0
- Ghidra address:
- BRGlide: 0x1006d530
◆ ApplyRigidBodyImpulse()
| void ApplyRigidBodyImpulse | ( | RigidBodyState * | state, |
| RigidBody * | body, | ||
| f32 | dt ) |
Add the force and torque of a body over a time to the velocity and angular velocity of a state.
- Parameters
-
state The state to change. body The body whose force and torque are added. dt The time over which they act.
- Ghidra address:
- USA: 0x80258324
- Ghidra address:
- Asia: 0x80257E74
- Ghidra address:
- EUR: 0x802598f4
- Ghidra address:
- JPN: 0x80259284
- Ghidra address:
- BRD3D: 0x100743a0
- Ghidra address:
- BRGlide: 0x1006d600
◆ QuaternionToMatrix()
| void QuaternionToMatrix | ( | f32 | out[4][4], |
| RigidBodyState * | state ) |
The 4 by 4 matrix of the orientation and position of a state.
- Parameters
-
out Receives the matrix. state The state.
- Ghidra address:
- USA: 0x802583dc
- Ghidra address:
- Asia: 0x80257F2C
- Ghidra address:
- EUR: 0x802599ac
- Ghidra address:
- JPN: 0x8025933c
- Ghidra address:
- BRD3D: 0x10074450
- Ghidra address:
- BRGlide: 0x1006d6b0
◆ IntegrateRigidBodyState()
| void IntegrateRigidBodyState | ( | RigidBodyState * | out, |
| RigidBodyState * | in, | ||
| f32 | dt ) |
Advance a state by a time, keeping its velocities.
- Parameters
-
out Receives the advanced state. in The state to advance. dt The time to advance by.
- Ghidra address:
- USA: 0x80258530
- Ghidra address:
- Asia: 0x80258080
- Ghidra address:
- EUR: 0x80259b00
- Ghidra address:
- JPN: 0x80259490
- Ghidra address:
- BRD3D: 0x100745f0
- Ghidra address:
- BRGlide: 0x1006d850
◆ SetRigidBodyForce()
| void SetRigidBodyForce | ( | RigidBodyForce * | force, |
| f32 | x, | ||
| f32 | y, | ||
| f32 | z, | ||
| f32 | pointX, | ||
| f32 | pointY, | ||
| f32 | pointZ, | ||
| s32 | frame ) |
Set the vector, the point, and the frame of a force.
- Parameters
-
force The force to set. x The x of the vector. y The y of the vector. z The z of the vector. pointX The x of the point the force acts at, in the frame of the body. pointY The y of the point. pointZ The z of the point. frame The frame of the vector, RIGID_BODY_FORCE_WORLD or RIGID_BODY_FORCE_BODY.
- Ghidra address:
- USA: 0x80258680
- Ghidra address:
- Asia: 0x802581D0
- Ghidra address:
- EUR: 0x80259c50
- Ghidra address:
- JPN: 0x802595e0
- Ghidra address:
- BRD3D: 0x100746e0
- Ghidra address:
- BRGlide: 0x1006d940
◆ Mtx4fInverseRotate()
The dot products of the rotation rows of a matrix with a vector, which turns a vector of the world into the frame of the matrix.
- Parameters
-
out Receives the vector in the frame of the matrix. m The matrix. v The vector in the world.
- Ghidra address:
- USA: 0x802586c0
- Ghidra address:
- Asia: 0x80258210
- Ghidra address:
- EUR: 0x80259c90
- Ghidra address:
- JPN: 0x80259620
- Ghidra address:
- BRD3D: 0x10074720
- Ghidra address:
- BRGlide: 0x1006d980
◆ Mtx3x3MulVec3f()
A vector times the rotation of a matrix, which turns a vector of the frame into the world.
- Parameters
-
out Receives the vector in the world. m The matrix. v The vector in the frame of the matrix.
- Ghidra address:
- USA: 0x80258758
- Ghidra address:
- Asia: 0x802582A8
- Ghidra address:
- EUR: 0x80259d28
- Ghidra address:
- JPN: 0x802596b8
- Ghidra address:
- BRD3D: 0x10074770
- Ghidra address:
- BRGlide: 0x1006d9d0
◆ Mtx4x4TransformPoint()
A point times a matrix, with its translation.
- Parameters
-
out Receives the transformed point. m The matrix. v The point.
- Ghidra address:
- USA: 0x802587e8
- Ghidra address:
- Asia: 0x80258338
- Ghidra address:
- EUR: 0x80259db8
- Ghidra address:
- JPN: 0x80259748
- Ghidra address:
- BRD3D: 0x100747c0
- Ghidra address:
- BRGlide: 0x1006da20
◆ Mtx3fMulVec3f()
A 3 by 3 matrix times a column vector.
- Parameters
-
out Receives the product. m The matrix. v The vector.
- Ghidra address:
- USA: 0x802588b8
- Ghidra address:
- Asia: 0x80258408
- Ghidra address:
- EUR: 0x80259e88
- Ghidra address:
- JPN: 0x80259818
- Ghidra address:
- BRD3D: 0x10074830
- Ghidra address:
- BRGlide: 0x1006da90
◆ ComputeRigidBodyAcceleration()
| void ComputeRigidBodyAcceleration | ( | RigidBody * | body | ) |
Turn the summed force and torque of a body into its accelerations.
- Parameters
-
body The body whose sums become its accelerations.
- Ghidra address:
- USA: 0x80258950
- Ghidra address:
- Asia: 0x802584A0
- Ghidra address:
- EUR: 0x80259f20
- Ghidra address:
- JPN: 0x802598b0
◆ ApplySingleForceWithDebug()
| void ApplySingleForceWithDebug | ( | RigidBody * | body, |
| RigidBodyForce * | force ) |
Add a force and its torque to the sums of a body, and print both on the debug output.
- Parameters
-
body The body. force The force to add.
- Ghidra address:
- USA: 0x802589f4
- Ghidra address:
- Asia: 0x80258544
- Ghidra address:
- EUR: 0x80259fc4
- Ghidra address:
- JPN: 0x80259954
◆ ApplyAllForcesToBody()
| void ApplyAllForcesToBody | ( | RigidBody * | body | ) |
Add each force of the list of a body to its sums of force and torque, printing each on the debug output.
- Parameters
-
body The body.
- Ghidra address:
- USA: 0x80258bdc
- Ghidra address:
- Asia: 0x8025872C
- Ghidra address:
- EUR: 0x8025a1ac
- Ghidra address:
- JPN: 0x80259b3c
◆ InitRigidBody()
| void InitRigidBody | ( | RigidBody * | body | ) |
Reset a body, and set the inertia of a box from its size and mass.
- Parameters
-
body The body, with its kind, size, and mass already set.
- Ghidra address:
- USA: 0x80258c24
- Ghidra address:
- Asia: 0x80258774
- Ghidra address:
- EUR: 0x8025a1f4
- Ghidra address:
- JPN: 0x80259b84
- Ghidra address:
- BRD3D: 0x10074870
- Ghidra address:
- BRGlide: 0x1006dad0
◆ BuildSkewSymmetricMatrix()
The matrix of the cross product with a vector.
- Parameters
-
out Receives the matrix. v The vector.
- Ghidra address:
- USA: 0x80258db0
- Ghidra address:
- Asia: 0x80258900
- Ghidra address:
- EUR: 0x8025a380
- Ghidra address:
- JPN: 0x80259d10
- Ghidra address:
- BRD3D: 0x100749d0
- Ghidra address:
- BRGlide: 0x1006dc30
◆ TransposeCopyMatrix3x3()
Copy the rotation of a matrix, and its transpose.
- Parameters
-
transpose Receives the transpose of the rotation. copy Receives the rotation. m The matrix.
- Ghidra address:
- USA: 0x80258e04
- Ghidra address:
- Asia: 0x80258954
- Ghidra address:
- EUR: 0x8025a3d4
- Ghidra address:
- JPN: 0x80259d64
- Ghidra address:
- BRD3D: 0x10074a10
- Ghidra address:
- BRGlide: 0x1006dc70
◆ Transpose4x4Into3x3()
The transpose of the rotation of a matrix.
- Parameters
-
out Receives the transpose. m The matrix.
- Ghidra address:
- USA: 0x80258e64
- Ghidra address:
- Asia: 0x802589B4
- Ghidra address:
- EUR: 0x8025a434
- Ghidra address:
- JPN: 0x80259dc4
- Ghidra address:
- BRD3D: 0x10074a50
- Ghidra address:
- BRGlide: 0x1006dcb0
◆ CopyMatrix4x4To3x3()
Copy the rotation of a matrix.
- Parameters
-
out Receives the rotation. m The matrix.
- Ghidra address:
- USA: 0x80258eac
- Ghidra address:
- Asia: 0x802589FC
- Ghidra address:
- EUR: 0x8025a47c
- Ghidra address:
- JPN: 0x80259e0c
- Ghidra address:
- BRD3D: 0x10074a90
- Ghidra address:
- BRGlide: 0x1006dcf0
◆ Mtx3fMultiply()
The product of two 3 by 3 matrices.
- Parameters
-
out Receives a times b, and must be neither factor. a The left factor. b The right factor.
- Ghidra address:
- USA: 0x80258ef8
- Ghidra address:
- Asia: 0x80258A48
- Ghidra address:
- EUR: 0x8025a4c8
- Ghidra address:
- JPN: 0x80259e58
- Ghidra address:
- BRD3D: 0x10074ac0
- Ghidra address:
- BRGlide: 0x1006dd20
◆ SubtractMatrix3x3()
The difference of two 3 by 3 matrices.
- Parameters
-
out Receives a minus b. a The matrix subtracted from. b The matrix subtracted.
- Ghidra address:
- USA: 0x80258f70
- Ghidra address:
- Asia: 0x80258AC0
- Ghidra address:
- EUR: 0x8025a540
- Ghidra address:
- JPN: 0x80259ed0
- Ghidra address:
- BRD3D: 0x10074b20
- Ghidra address:
- BRGlide: 0x1006dd80
◆ MtxBuildScaledInverse()
The inverse of a rigid transform whose axes are scaled.
- Parameters
-
m The transform. out Receives the inverse. scale The factors the columns of the inverted rotation are scaled by.
- Ghidra address:
- USA: 0x80258fd4
- Ghidra address:
- Asia: 0x80258B24
- Ghidra address:
- EUR: 0x8025a5a4
- Ghidra address:
- JPN: 0x80259f34
- Ghidra address:
- BRD3D: 0x10074b70
- Ghidra address:
- BRGlide: 0x1006ddd0
◆ SolveLinearSystem3x3()
Solve a system of three linear equations by Cramer's rule.
- Parameters
-
out Receives the solution. a The coefficients. b The constants.
- Ghidra address:
- USA: 0x802590e8
- Ghidra address:
- Asia: 0x80258C38
- Ghidra address:
- EUR: 0x8025a6b8
- Ghidra address:
- JPN: 0x8025a048
- Ghidra address:
- BRD3D: 0x10074c10
- Ghidra address:
- BRGlide: 0x1006de70
Generated by
 1.15.0