The PI manager, the PI access queue, and the PI handles of the cartridge and the 64DD. More...
#include <ultra64.h>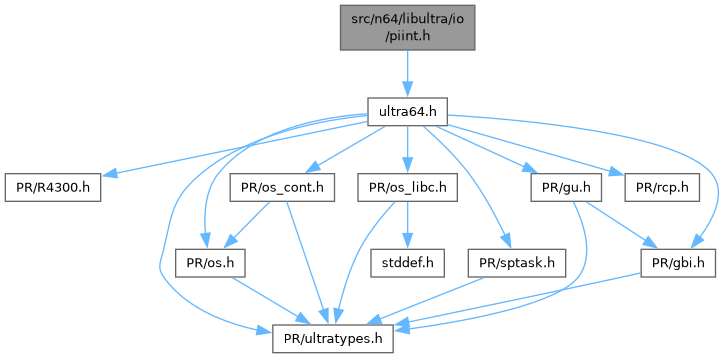
Go to the source code of this file.
Macros | |
| #define | WAIT_ON_IOBUSY(stat) |
| Wait while the PI is busy with a DMA or an I/O access. | |
| #define | LEO_BASE_REG 0x05000000 |
| #define | LEO_C2_BUFF (LEO_BASE_REG + 0x000) |
| #define | LEO_SECTOR_BUFF (LEO_BASE_REG + 0x400) |
| #define | LEO_STATUS (LEO_BASE_REG + 0x508) |
| #define | LEO_BM_CTL (LEO_BASE_REG + 0x510) |
| #define | LEO_BM_STATUS (LEO_BASE_REG + 0x510) |
| #define | LEO_STATUS_DATA_REQUEST 0x40000000 |
| #define | LEO_STATUS_C2_TRANSFER 0x10000000 |
| #define | LEO_STATUS_BUFFER_MANAGER_ERROR 0x08000000 |
| #define | LEO_STATUS_MECHANIC_INTERRUPT 0x02000000 |
| #define | LEO_BM_CTL_START 0x80000000 |
| #define | LEO_BM_CTL_RESET 0x10000000 |
| #define | LEO_BM_CTL_CLR_MECHANIC_INTR 0x01000000 |
| #define | LEO_BM_STATUS_MICRO 0x02000000 |
| #define | LEO_BM_STATUS_C1DOUBLE 0x00400000 |
| #define | LEO_BM_STATUS_C1SINGLE 0x00200000 |
| #define | LEO_CMD_TYPE_0 0 |
| #define | LEO_CMD_TYPE_1 1 |
| #define | LEO_CMD_TYPE_2 2 |
| #define | LEO_TRACK_MODE 2 |
| #define | LEO_SECTOR_MODE 3 |
| #define | LEO_ERROR_GOOD 0 |
| #define | LEO_ERROR_4 4 |
| #define | LEO_ERROR_22 22 |
| #define | LEO_ERROR_23 23 |
| #define | LEO_ERROR_24 24 |
| #define | LEO_ERROR_29 29 |
Detailed Description
The PI manager, the PI access queue, and the PI handles of the cartridge and the 64DD.
Macro Definition Documentation
◆ WAIT_ON_IOBUSY
| #define WAIT_ON_IOBUSY | ( | stat | ) |
Wait while the PI is busy with a DMA or an I/O access.
The status is read once before the loop tests it, and again on each pass.
◆ LEO_BASE_REG
| #define LEO_BASE_REG 0x05000000 |
The base address of the 64DD registers.
◆ LEO_C2_BUFF
| #define LEO_C2_BUFF (LEO_BASE_REG + 0x000) |
The buffer of the C2 error correction.
◆ LEO_SECTOR_BUFF
| #define LEO_SECTOR_BUFF (LEO_BASE_REG + 0x400) |
The buffer of a sector.
◆ LEO_STATUS
| #define LEO_STATUS (LEO_BASE_REG + 0x508) |
The status register.
◆ LEO_BM_CTL
| #define LEO_BM_CTL (LEO_BASE_REG + 0x510) |
The buffer manager control, on write.
◆ LEO_BM_STATUS
| #define LEO_BM_STATUS (LEO_BASE_REG + 0x510) |
The buffer manager status, on read.
◆ LEO_STATUS_DATA_REQUEST
| #define LEO_STATUS_DATA_REQUEST 0x40000000 |
The drive requests data.
◆ LEO_STATUS_C2_TRANSFER
| #define LEO_STATUS_C2_TRANSFER 0x10000000 |
A C2 transfer is ready.
◆ LEO_STATUS_BUFFER_MANAGER_ERROR
| #define LEO_STATUS_BUFFER_MANAGER_ERROR 0x08000000 |
The buffer manager reported an error.
◆ LEO_STATUS_MECHANIC_INTERRUPT
| #define LEO_STATUS_MECHANIC_INTERRUPT 0x02000000 |
The mechanism raised an interrupt.
◆ LEO_BM_CTL_START
| #define LEO_BM_CTL_START 0x80000000 |
Start the buffer manager.
◆ LEO_BM_CTL_RESET
| #define LEO_BM_CTL_RESET 0x10000000 |
Reset the buffer manager.
◆ LEO_BM_CTL_CLR_MECHANIC_INTR
| #define LEO_BM_CTL_CLR_MECHANIC_INTR 0x01000000 |
Clear the interrupt of the mechanism.
◆ LEO_BM_STATUS_MICRO
| #define LEO_BM_STATUS_MICRO 0x02000000 |
The micro error.
◆ LEO_BM_STATUS_C1DOUBLE
| #define LEO_BM_STATUS_C1DOUBLE 0x00400000 |
A C1 double error.
◆ LEO_BM_STATUS_C1SINGLE
| #define LEO_BM_STATUS_C1SINGLE 0x00200000 |
A C1 single error.
◆ LEO_CMD_TYPE_0
| #define LEO_CMD_TYPE_0 0 |
A transfer command of type 0.
◆ LEO_CMD_TYPE_1
| #define LEO_CMD_TYPE_1 1 |
A transfer command of type 1.
◆ LEO_CMD_TYPE_2
| #define LEO_CMD_TYPE_2 2 |
A transfer command of type 2.
◆ LEO_TRACK_MODE
| #define LEO_TRACK_MODE 2 |
Transfer a whole track.
◆ LEO_SECTOR_MODE
| #define LEO_SECTOR_MODE 3 |
Transfer one sector.
◆ LEO_ERROR_GOOD
| #define LEO_ERROR_GOOD 0 |
The transfer succeeded.
◆ LEO_ERROR_4
| #define LEO_ERROR_4 4 |
Error 4 of the 64DD.
◆ LEO_ERROR_22
| #define LEO_ERROR_22 22 |
Error 22 of the 64DD.
◆ LEO_ERROR_23
| #define LEO_ERROR_23 23 |
Error 23 of the 64DD.
◆ LEO_ERROR_24
| #define LEO_ERROR_24 24 |
Error 24 of the 64DD.
◆ LEO_ERROR_29
| #define LEO_ERROR_29 29 |
Error 29 of the 64DD.
Generated by
 1.15.0